01 — PHD RESEARCHER / ROBOTICS & AUTONOMY

Morphable, omnidirectional
aerial robotics.

I'm Jose Diaz, a PhD researcher in the Intelligent Robotics & Autonomy Lab at the University of Michigan, advised by Prof. Vasileios Tzoumas. I design and fly drones with full 6-DoF force and torque control — for agile maneuvering, aerial manipulation, and resilience.

My work spans the full stack: controls, firmware, simulation, and hardware flight test. M.S. (concentration in Controls & Autonomous Systems) & B.S. in Aerospace Engineering at Michigan, Summa Cum Laude.

Portrait of Jose Diaz
LOC: ANN ARBOR, MI
diazjose [at] umich [dot] edu

02 — PUBLICATIONS

2 PAPERS
CO-FIRST AUTHOR UNDER REVIEW 2 U.S. PATENTS PENDING

MorphQuad: A Morphable Quadrotor for Superhuman Maneuverability, Manipulation, and Resiliency

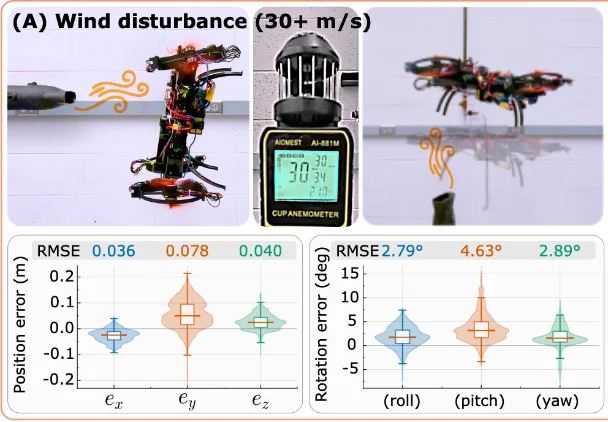
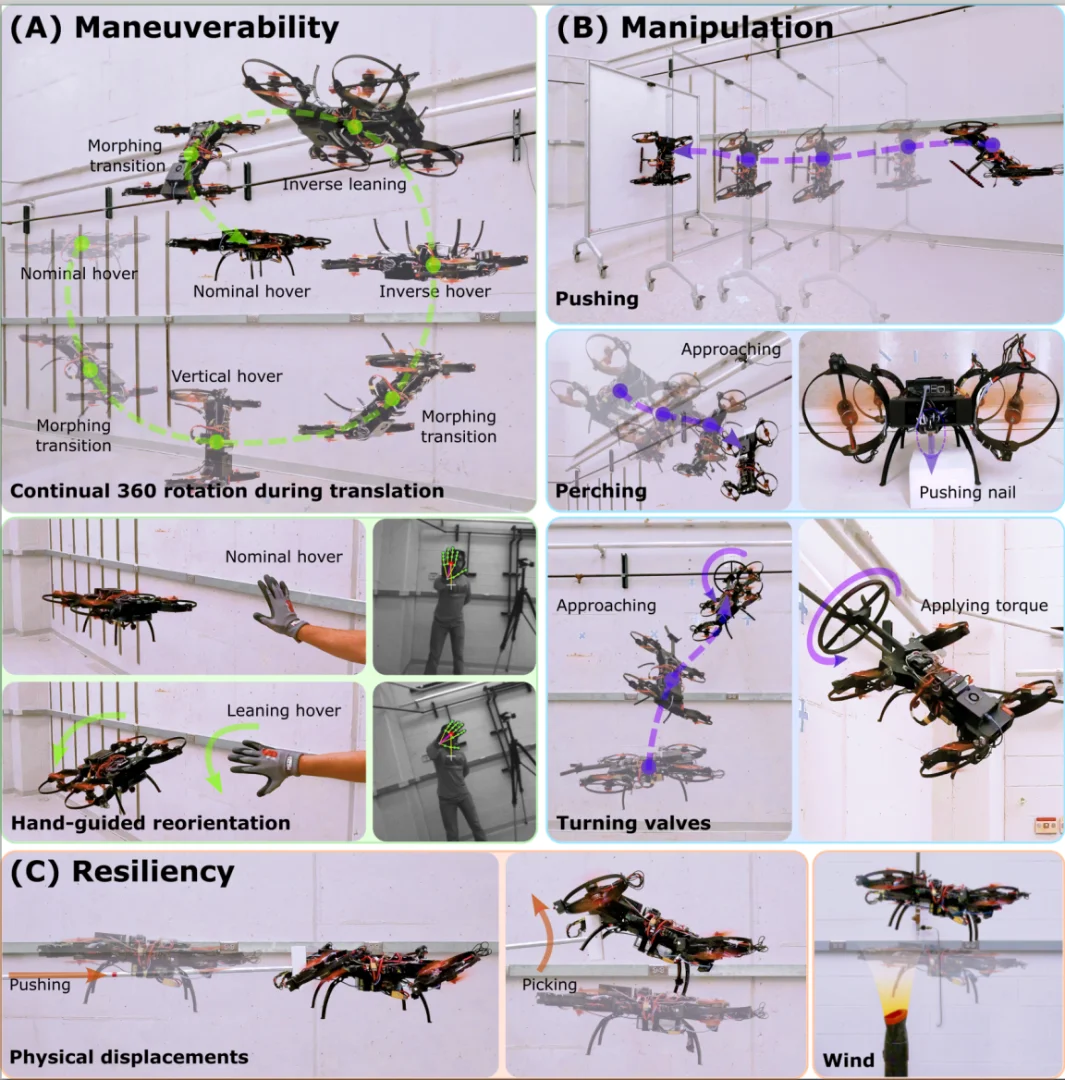
A morphable quadrotor that acts as a flying human hand — navigating tight spaces, turning valves, perching, pointing and tracking, pushing and pulling. With full 6-DoF control at any orientation, it stays resilient to winds, physical displacements, and even rotor failures.
J. C. Díaz Peón González Pacheco*, J. Xu*, A. Zhao*, H. Zhou, A. Navsalkar, A. Scheffer, A. Malli Reddi, S. Shankar, Y. Bao, V. Tzoumas
*equal first-author contribution · iRAL — University of Michigan

MorphQuad overview figure in three panels. (A) Maneuverability: continuous 360° rotation during translation, and hand-guided reorientation. (B) Manipulation: pushing, perching, pushing a nail, turning valves, and applying torque. (C) Resiliency: recovering from physical displacements and rejecting wind.
MANEUVER
Traverses tight spaces from any direction.
MANIPULATE
Turns valves, pushes, and presses sensors.
RESILIENT
Rejects wind and contact disturbances.
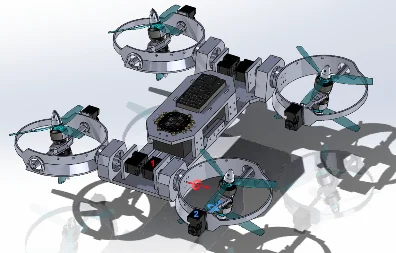
CAD render of MorphEUS, a quadrotor with four ducted coaxial rotor pods mounted on tilting arms
CO-FIRST AUTHOR ICRA 2025 WORKSHOP U.S. PATENT AWARDED

MorphEUS: A Morphable Omnidirectional Unmanned System

A fully omnidirectional, variable-tilt coaxial quadrotor with independent 6-DoF force/torque control, augmented by an L1-adaptive controller for robustness. Presented at the ICRA 2025 Workshop on Open Challenges in Robotics for Asset Inspection and Management.

I. Bao, J. C. Díaz Peón González Pacheco, A. Navsalkar, A. Scheffer, S. Shankar, A. Zhao, H. Zhou, V. Tzoumas
All authors contributed equally; listed alphabetically.

03 — PROJECTS